Robust Mobility
Conquer Complex Terrains
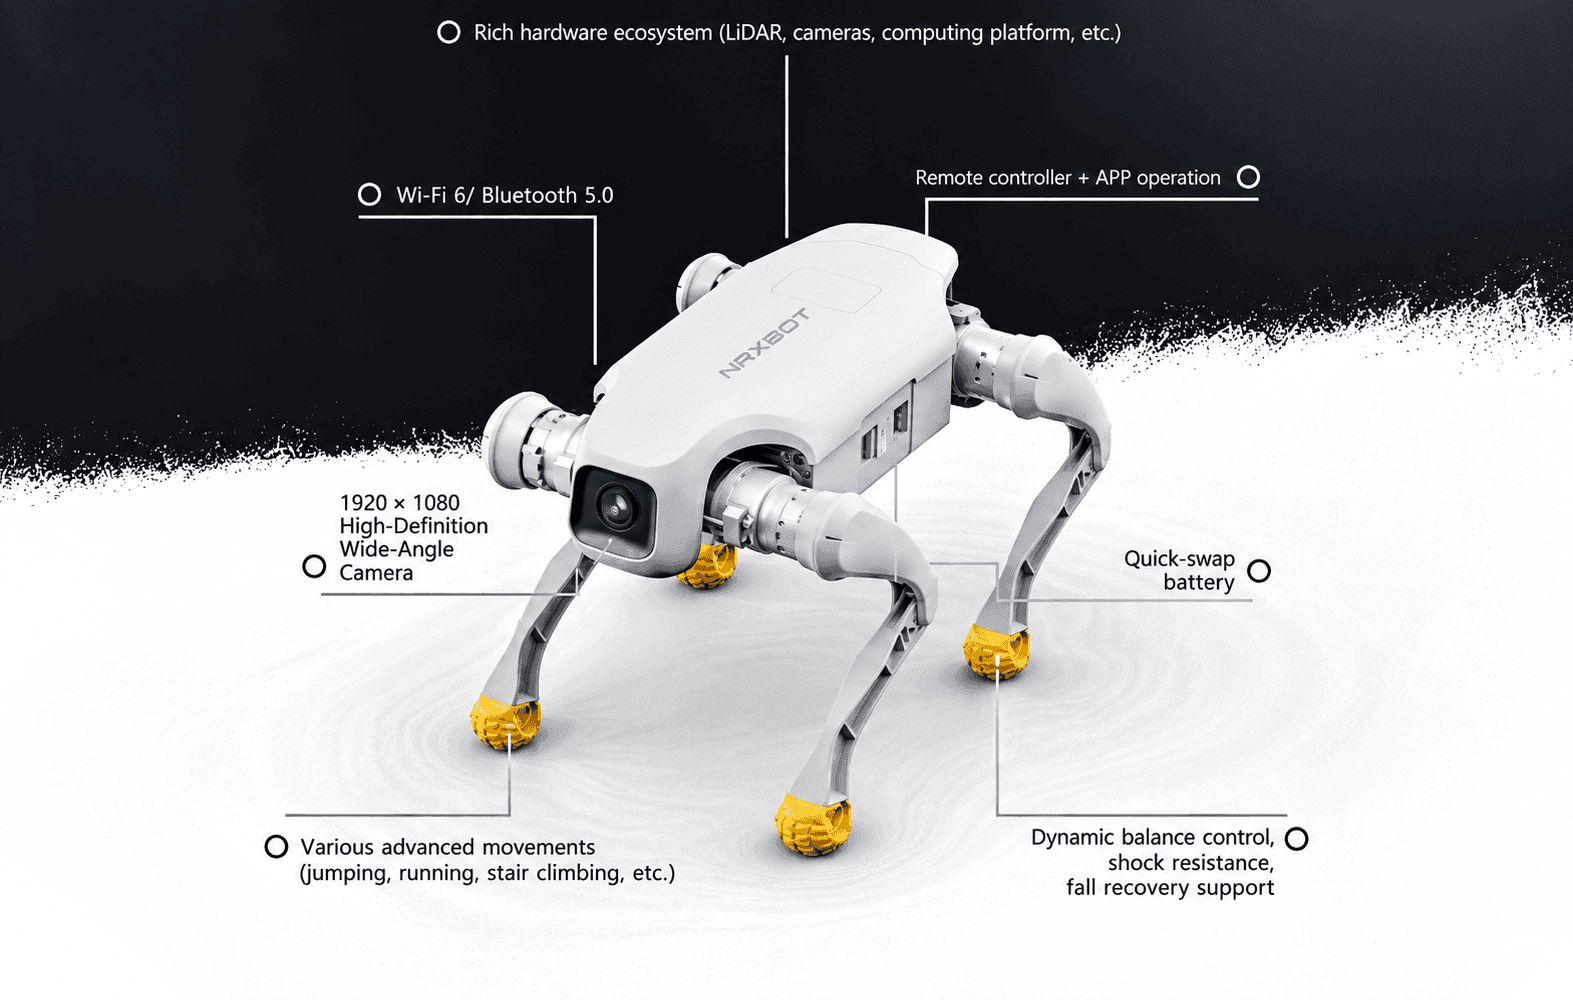
Powered by RL-based reinforcement learning gait control, it autonomously adapts to diverse and challenging terrains.Equipped with self-balancing, anti-fall, and anti-interference capabilities.
High-Performance Motor
- High Torque
- Impact Resistant
- Zero Calibration Required
Peak torque of 48 N·m with high output torque, enabling reliable operation in complex terrains and under heavy loads
Dual encoder control eliminates the need for zero calibration, enabling immediate operation upon startup
Flexible Development
Compatible with a wide range of modules and payload integration
Edu version provides SDK development kit, supporting payload integration
Offers standardized interfaces, compatible with various modules, enabling multi-scenario application development
Compatible with positioning modules, LiDAR, depth cameras, RTK modules, 4G/5G modules, and image transmission modules
Provides URDF modeling, supporting simulation and testing in Isaac Sim and MuJoCo environments
Flexible Development
Package Contents
D1 Robot Dog Platform*1unit
Charger*1piece
Handheld Remote*1piece
Flexible Development
Specifications
| Category | D1 Pro | D1 Edu |
|---|---|---|
| Basic Information | ||
| Material | Aluminum alloy + High-strength engineering plastic | Aluminum alloy + High-strength engineering plastic |
|
Standing Size (L×W×H) |
Approx. 635mm × 360mm × 420mm | Approx. 635mm × 360mm × 420mm |
|
Lying Size (L×W×H) |
Approx. 675mm × 435mm × 145mm | Approx. 675mm × 435mm × 145mm |
|
Weight (incl. battery) |
15.5kg | 15.5kg |
| Operating Temperature | 0℃~40℃ | 0℃~40℃ |
| Charging Time | Approx. 1 hour (10% to 90% charge) | Approx. 1 hour (10% to 90% charge) |
| Endurance Time | 1-2h | 1-2h |
| Range | 6km ± 1km | 6km ± 1km |
| Performance Parameters | ||
| Computing Power | 8-core high-performance CPU | 8-core high-performance CPU |
| Max. Power Output | 3500W | 3500W |
| Max. Speed | 3.5m/s | 3.5m/s |
| Effective Payload | 5kg | 5kg |
|
Continuous Stair Climb Height |
16cm | 16cm |
| Max. Climbing Slope | 40° | 40° |
|
Jumping Height (off ground) |
35cm | 35cm |
| Joint Parameters | ||
| Actuator Type | High power density motion unit | High power density motion unit |
| Max. Joint Torque | 48N·m | 48N·m |
|
Aluminum Alloy Precision Joint Motors |
12 | 12 |
|
Joint Range (Body) |
-28°~28° | -28°~28° |
|
Joint Range (Thigh) |
-170°~66° | -170°~66° |
|
Joint Range (Lower Leg) |
35°~156° | 35°~156° |
| Camera FOV |
DFOV122°, HFOV111°, VFOV70° |
| Sensors | ||
| IMU | Standard | Standard |
| Functions | ||
| Standard Actions |
Standing, Lying, Damping Mode, Pitch Adjustment, Height Adjustment, Horizontal Turning |
| Special Actions |
Forward jump, upward jump, biped standing, backflip, waving etc |
| Real-time Image Transmission | Supported | Supported |
| Secondary Development | Not supported | Supported |
| Expansion Interfaces | None |
Ethernet, USB, Power Port, SBUS Port, UART Port |
| Battery | Nominal 4.6Ah, Voltage 43.2V | Nominal 4.6Ah, Voltage 43.2V |
| Accessories | ||
| Adapter | Standard | Standard |
| Charging Base | Standard | Standard |
| Handheld Controller | Standard | Standard |
| Others | ||
| Warranty | 1 year | 1 year |