OmniHand Pro 2025
High-Integration Multi-Functional Dexterous Hand Enhanced Perception, More Capabilities
Human-like Size | All-around Operation | Superior Perception
Human-sized
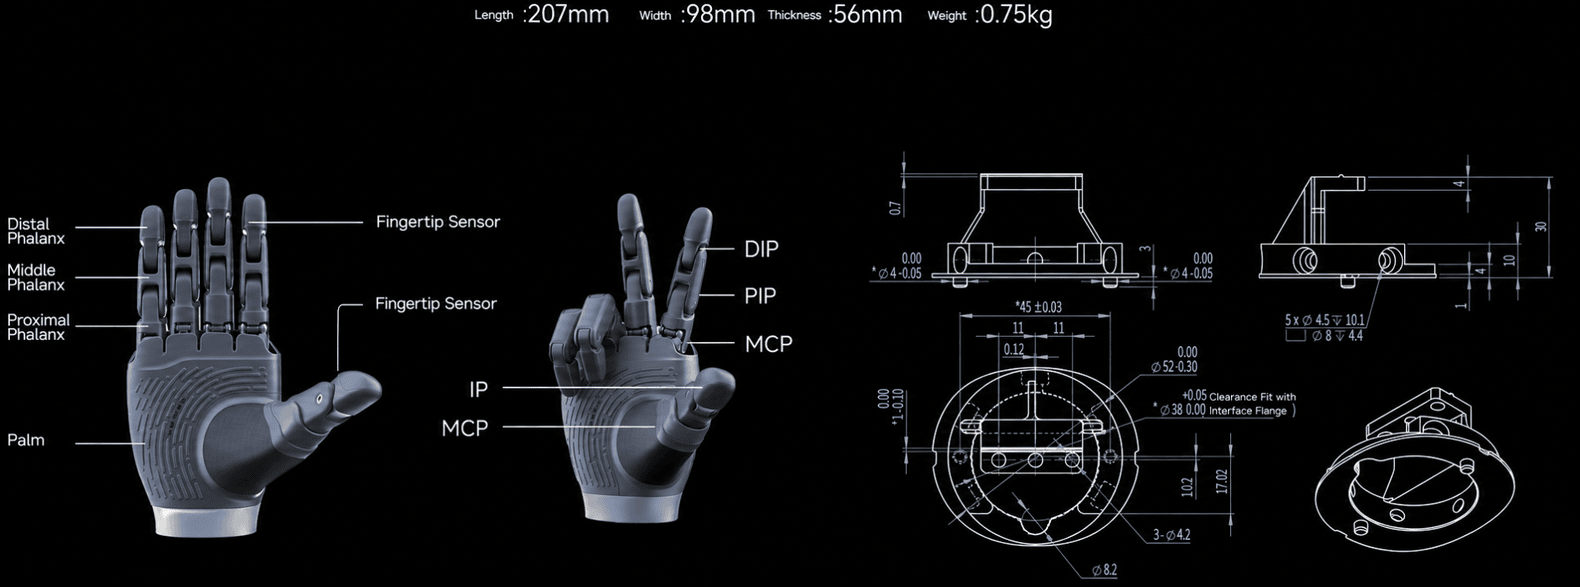
19 degrees of freedom, weighing only 750g Smaller, lighter, and more human-like among dexterous hands with the same configuration
All-round Operation
Optimized structural design Effortless handling of professional tools Maximum fingertip force of 20N with one hand
High-Sensitivity Perception
Multi-modal sensing (position, normal force, tangential force, proximity).
Achieves up to 0.01N-level sensitivity with intelligent algorithms
Package Contents
OmniHand ×1
CANFD Communication Cable
×1

Power Cable ×1

Certificate of Conformity ×1
Product Parameters
| Category | Parameter | OmniHand Pro 2025 |
|---|---|---|
|
Main Unit Specifications |
Model | OmniHand Pro 2025 |
| Weight | ≤750g | |
| Size | 207 × 98 × 56 mm | |
| Material | PA + Silicone | |
| Active DOF | 12 | |
| Total DOF | 19 | |
| Transmission | Linkage transmission | |
| Drive Method | Motor + Screw Rod | |
| Number of Joints | 19 | |
| Joint Range |
Four fingers flexion: 80°
Four fingers abduction/adduction: ±10°
Thumb flexion: 50°
Thumb abduction/adduction: 90°
Thumb rotation: 50°
|
|
| Minimum Closing Time (typ.) | 0.8s | |
| Minimum Grasp Diameter | 2mm | |
| Finger Reposition Accuracy (typ.) | 0.02mm | |
| Max Fingertip Force (typ.) | 20N | |
| Operating Voltage | 12~24V | |
| Idle Current | 0.5A | |
| Max Current | 4.5A | |
| Communication Interface | CANFD | |
| Operating Temperature | -20~50℃ | |
|
Load Capacity (Palm Up, 5 cm Rigid Object) |
35kg | |
|
Load Capacity (Palm Down, 5 cm Rigid Object) |
5kg | |
|
Perception Specifications |
Sensor Array Configuration |
Fingertip 3-axis force; Palm 1-axis force; 150+ tactile points |
| Resolution | 0.01N | |
| Sensing Range | 0~50N | |
| Max Permissible Force (Non-Destructive) | 1000N | |
|
Software Functions |
OS Compatibility | Windows |
| Communication Rate | 1kHz | |
| Data Packet Size | 48 bytes | |
| Sensory Feedback |
Joint position
Joint speed
Joint torque
Joint temperature
Electrical current
Tactile pressure information
|
|
| Control Modes |
Speed mode
Position mode
Force mode
Hybrid position-force mode
Tactile mode
|
|
| Secondary Development | Supported | |
| Others | Compatibility | Compatible with others |
Contact us
Let’s Build the Future Together
Have a question about our robotic solutions or want to explore how NRX BOT can support your needs?
Get in touch with our team to discuss products, applications, or any other enquiries. We’d be happy to connect with you.